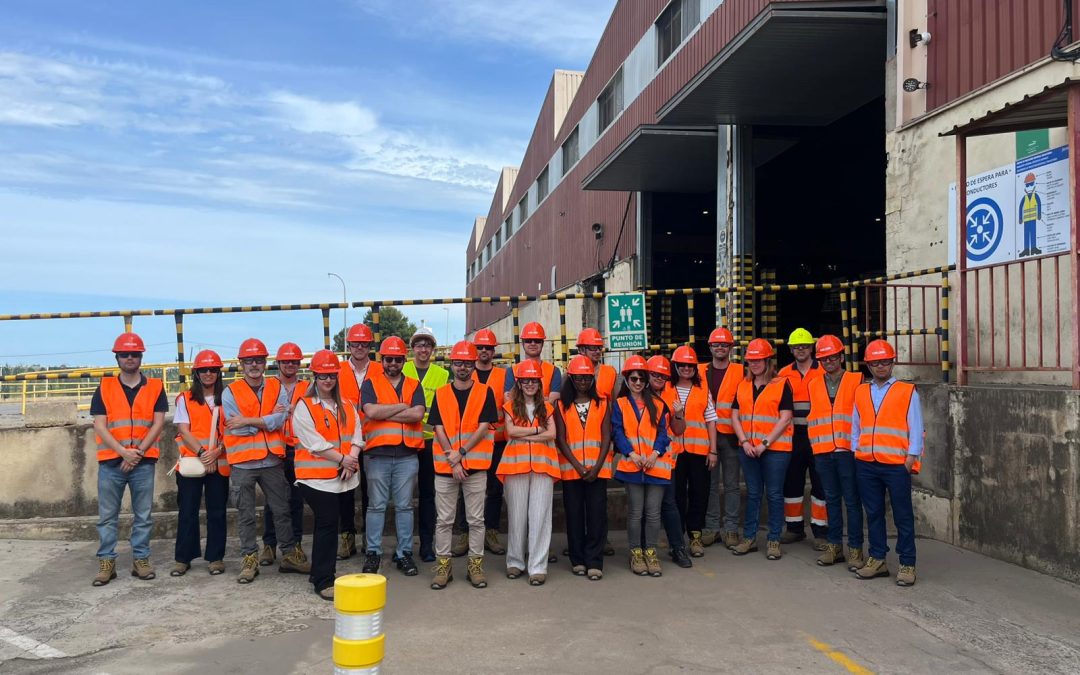
Following iBot4CRMs participation at the ADRF 2026 in Porto, Portugal next week, the consortium will meet on Oct 15-16 to discuss the project updates, especially from our Pilot Scenarios, Perception and AI approach, and AI-boosted robotics for complex dismantling of Hard Disk Drive (HDD).
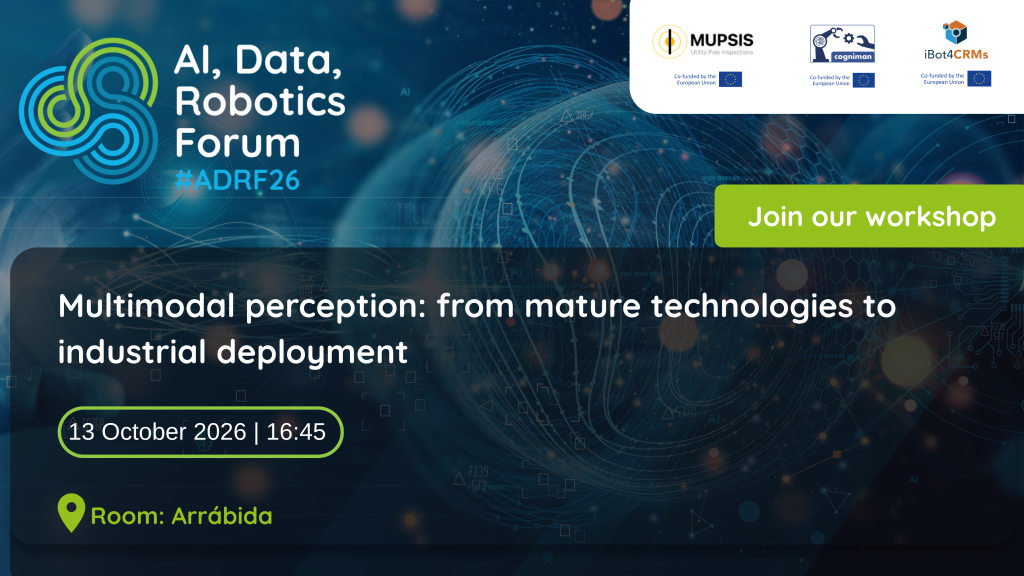
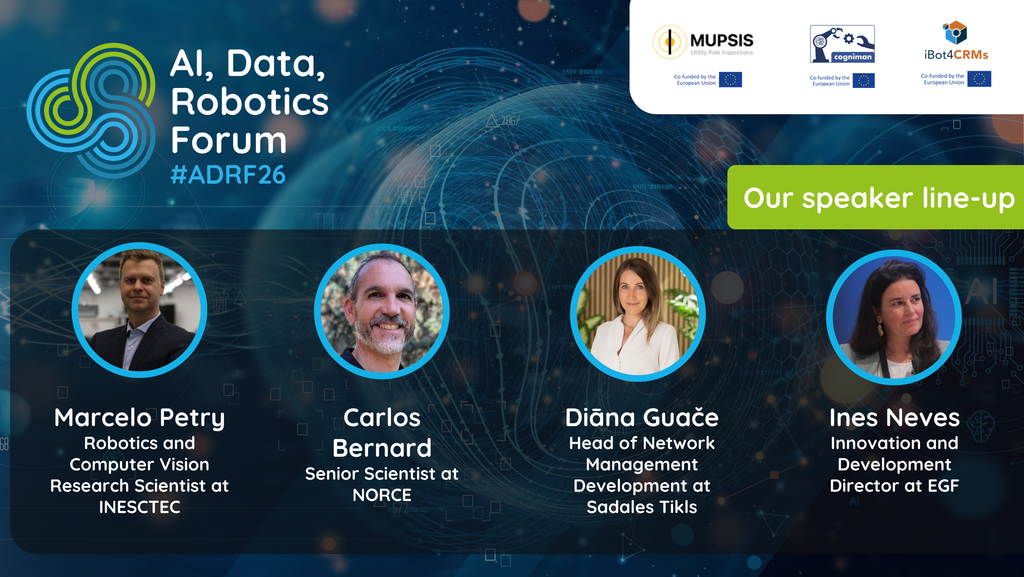
Next week (13-14 October), our project will participate in a workshop on “Multimodal Perception” with EU-funded projects like COGNIMAN, MUPSIS and AERONEX. We will also share a booth with COGNIMAN at ADRF, so drop by at booth number 26.
Here’s what iBot4CRMs will review in the meeting:
Work Package 1: Pilot specifications and trials
As a cornerstone of the project, this Work Package will guide the development of the Pilot Scenarios, including testing and validation. In the project, we will show a range of technologies, highlighting the benefits of integrating AI, Data Analytics, and Robotics into various recovery and recycling processes for Waste Electrical and Electronic Equipment, including PCBs, FPDs, desktops (WEEE), End-of-Life Vehicles (ELVs), Electric Vehicles (EVs), and waste from slag stream after incineration.
So, this consortium meeting will help to realign and refocus project activities with the targets around testing and validation of the Pilot Scenarios to create the impact we are expecting.
Work Package 3: Perception and AI
Advanced sensing capabilities are needed for an enhanced robotic perception and guidance. This will help the robots to detect, dismantle and recover Critical Raw Materials from heterogenous waste streams. Usually, these operations take place in dynamic environments where a lot depends on the size, type and composition of waste materials coming into the conveyor belt. In our project, we are utilising a combination of these perception technologies, such as 2D/3D optical imaging, spectral and thermal imaging (for material composition), X-Ray Fluorescence (XRF) for radar imaging and haptic sensing (sense of touch).
Within this advanced perception operation, we will use XRF and spectral imaging for detecting copper and tin as well as haptic sensors for dismantling. The intention is to demonstrate the capabilities of the AI-assisted robots in selected scenarios for dismantling and recovery of CRMs from urban waste streams.
NORCE has made some progress in the XRF results for Pilot Scenario 7 (Recovery of CRMs from a stream of slag originated after waste incineration) with their own XRF instrument. Meanwhile, ITA, NORCE and PICVISA are working on their perception systems that will be installed at EKAN and VALORUSL facilities soon.
Watch our project video:
Work Package 4: AI-boosted robotics for optimised complex manipulation
For Pilot Scenario 1 (Recovery and recycling of Neodymium magnets with robots dismantling used EMs), INESC TEC is working on the dismantling station. Regarding this, INESC TEC will provide a video demonstration to the consortium.
For Scenarios 2 (Dismantling Flat Panel Display (FPD) and recovery of CRMs) and 3 (Recovery and recycling of Neodymium magnets with robots dismantling desktops), INESC TEC has acquired images of Hard Disk Drives (HDDs) to train and improve the dismantling process.
Related to the work mentioned above, you can download two papers from INESC TEC by going to our Media Library here.
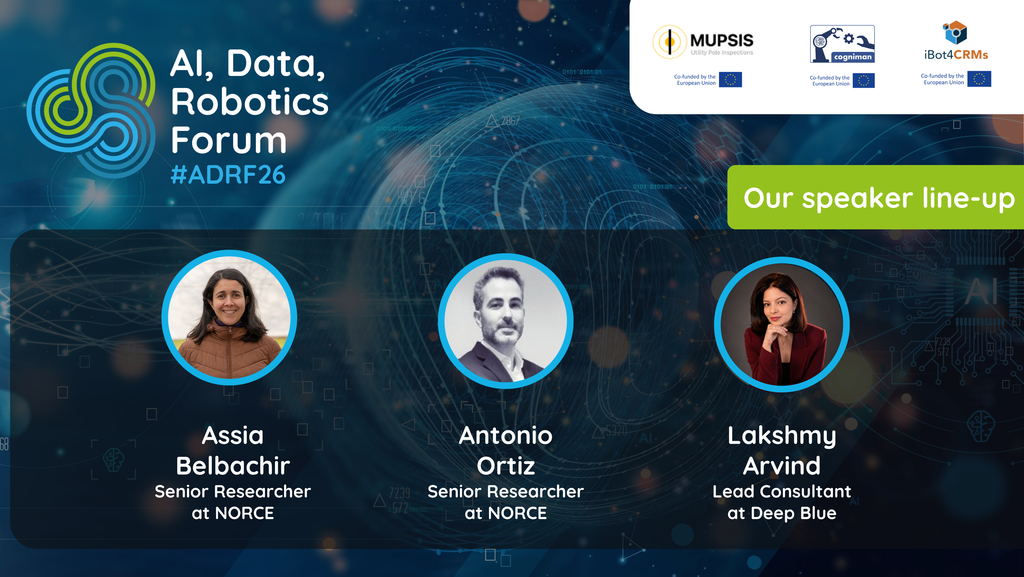
Meanwhile, here are a few details about the workshop and speakers below:
For more information, click here.